Products
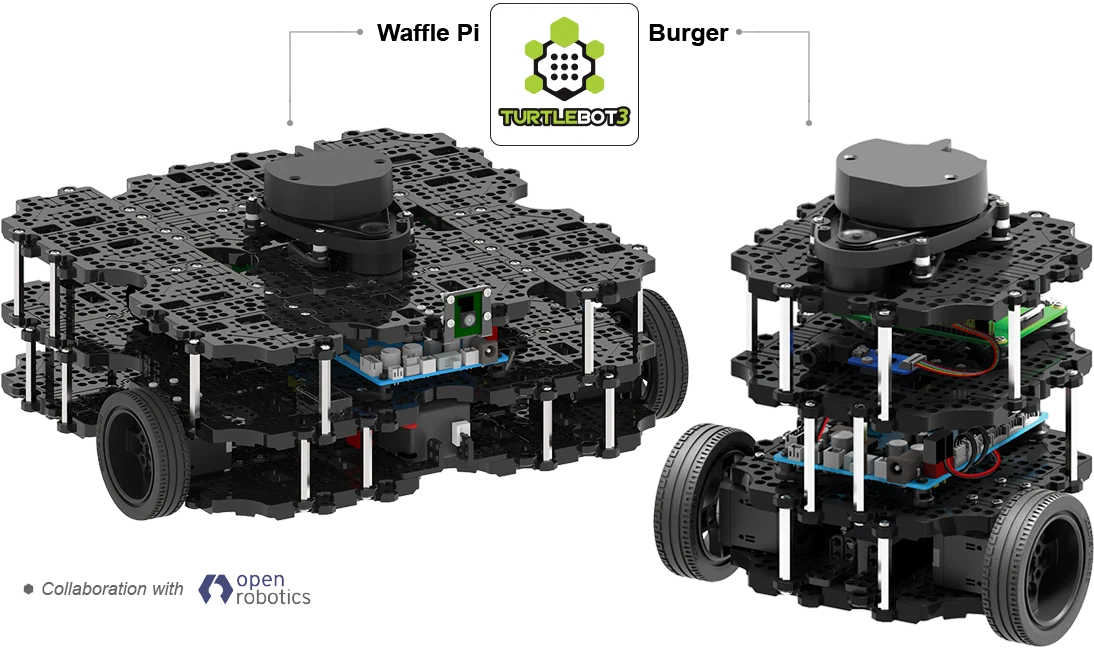
ROBOTIS TurtleBot3 Waffle Pi Mobile Robot
TurtleBot3 Waffle Pi is an open-source, two-wheeled differential-drive mobile robot platform for education, research and prototyping, with a camera-equipped configuration. ROBOTIS's English e-Manual lists a maximum translational speed of 0.26 m/s, a 30 kg maximum payload, 281 × 306 × 141 mm dimensions, an assembled weight of 1.8 kg including the SBC, battery and sensors, and an expected operating time of 2 hours. The documented configuration includes Raspberry Pi 4, OpenCR, a 360-degree LDS-02 laser distance sensor, Raspberry Pi Camera Module v2.1 and XM430-W210 wheel actuators. It is a ROS-based platform; values below follow the official Waffle Pi specification table.
Manufacturer product page: https://en.robotis.com/model/page.php?co_id=prd_turtlebot3
English technical documentation: https://emanual.robotis.com/docs/en/platform/turtlebot3/features/
Manufacturer category: DYNAMIXEL SYSTEM / TurtleBot3
Specifications
| Product model | TurtleBot3 Waffle Pi |
|---|---|
| Drive configuration | differential |
| Navigation method | SLAM_LiDAR |
| Rated payload | 30 kg |
| Maximum speed | 0.26 m/s (translational) |
| Typical runtime | 2 h (expected operating time) |
| Dimensions | 281 × 306 × 141 mm (L × W × H) |
| Weight | 1.8 kg (including SBC, battery and sensors) |
| Charging method | manual_plug |
| Technical extension parameters | Expected charging time: 2 h 30 min. Raspberry Pi 4 SBC; OpenCR 1.0 MCU; XM430-W210 actuators; 360-degree LDS-02 laser distance sensor; Raspberry Pi Camera Module v2.1; 9-axis IMU; 11.1 V, 1800 mAh, 19.98 Wh Li-Po battery; ROS-based mobile robot platform. |